Robot Inverse Kinematics & Motion Planning
Fast inverse kinematics and trajectory planning for redundant and hyper-redundant manipulators, with multi-solution generation and constraint-aware selection.
I'm Ewan Lin (Yuanlin Yi), a master's student in mechanics at Hefei University of Technology, working on robot motion planning, mechanics simulation, and structural optimization. My work lives at the intersection of mechanics and machine learning: I bring deep generative models, surrogate modeling, and intelligent optimization into classical mechanical-engineering problems — using conditional normalizing flows for fast inverse kinematics of redundant manipulators, and Kriging surrogates to drive lightweight structural design. I believe the intersection of mechanics and AI can make engineering design and robotic control more efficient and more intelligent.
Current focus
Generative models and optimization for robot inverse kinematics and lightweight design
Research
Fast inverse kinematics and trajectory planning for redundant and hyper-redundant manipulators, with multi-solution generation and constraint-aware selection.
Applying conditional normalizing flows and other deep generative models to physical and mechanical problems where one input admits many valid solutions.
Kriging and data-driven surrogates that replace expensive finite-element simulation, combined with intelligent optimization for constrained lightweight design.
Parametric modeling and automated simulation with Abaqus, ANSYS, and SolidWorks, including Python-driven secondary development for batch data generation.
Projects
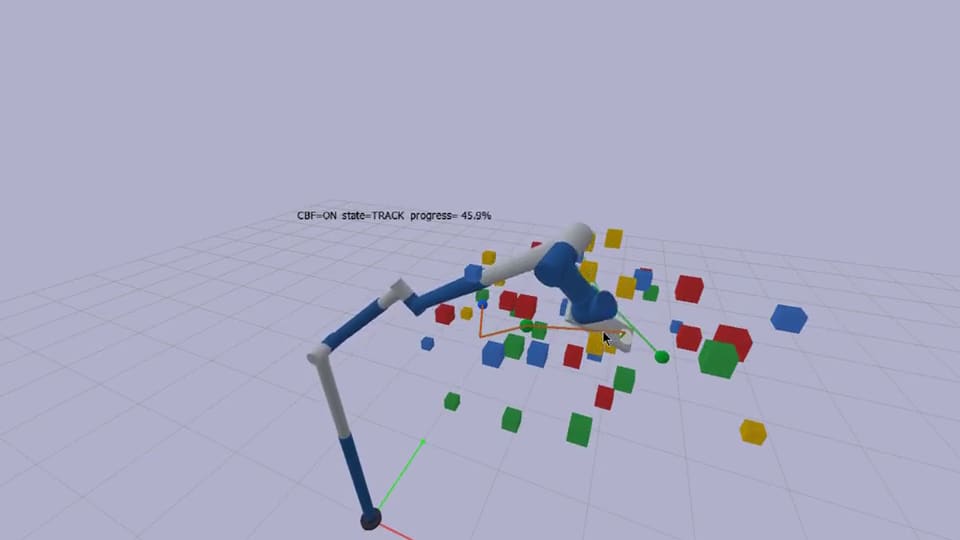
Oct 2024 — Present
Conditional normalizing flow for an 8-DOF hybrid-joint redundant manipulator: sample multiple feasible IK solutions, filter by joint limits, collisions and continuity, then plan and track with CBFs.
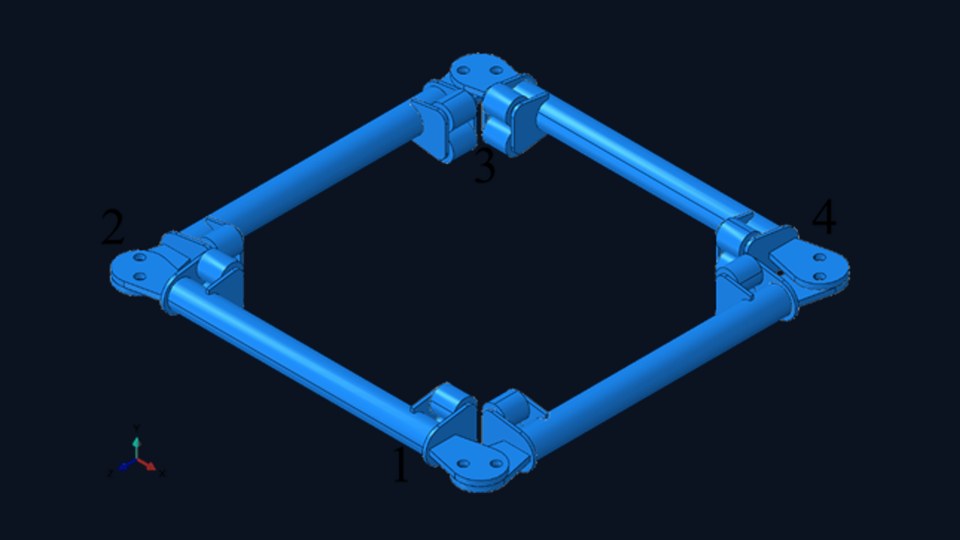
Nov 2024 — Jun 2025
Global FEA plus local roller–angle-steel contact on the first waist ring; then fewer rollers and a Kriging + GWO search of the pipe section.
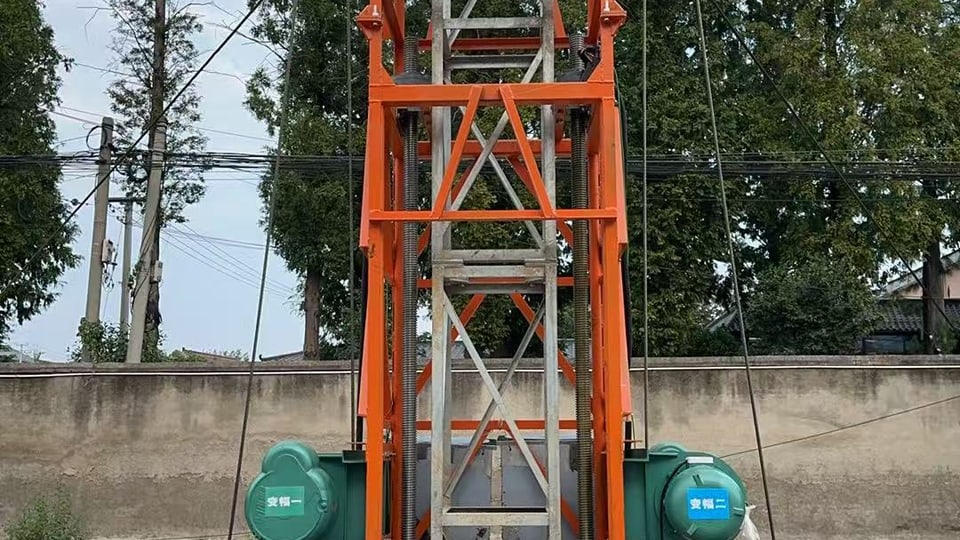
Jul 2025 — Present
Replace the rope hoist of a power-tower lifting frame with an integrated lead-screw drive; size the motor and platform, model the assembly in SolidWorks, and check strength and stiffness in ANSYS.
Publications & Patents
Haolong Chen, Yuanlin Yi, et al.(JCR Q1 / SCI)
International Journal of Heat and Mass Transfer
Yuanlin Yi, Haolong Chen, Zhijie Li, et al.
Journal of Mechanical Engineering (under review)
Recognition
Hefei University of Technology