Oct 2024 — Present
Generative Inverse-Kinematics Solver for Redundant Manipulators
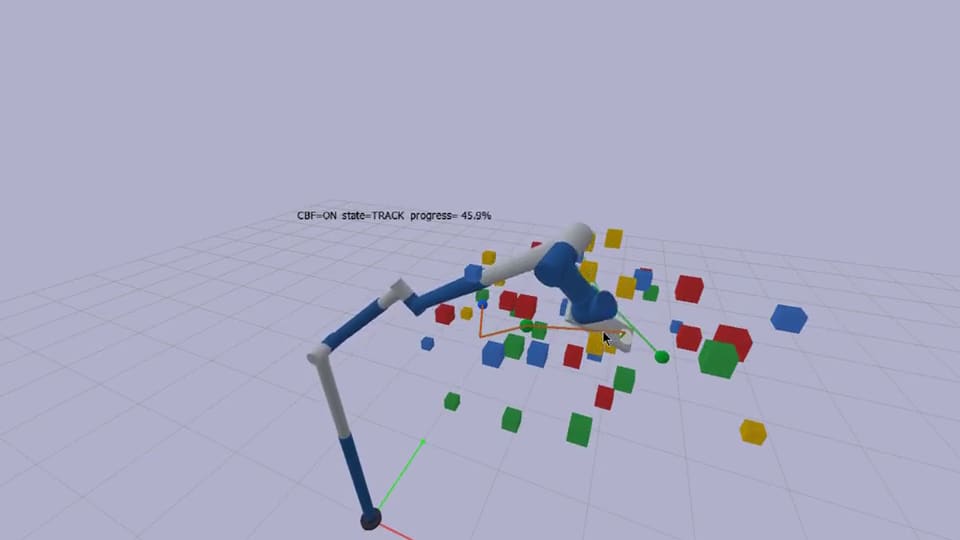
Conditional normalizing flow for an 8-DOF hybrid-joint redundant manipulator: sample multiple feasible IK solutions, filter by joint limits, collisions and continuity, then plan and track with CBFs.
FeaturedOngoing
Inverse KinematicsNormalizing FlowsTrajectory PlanningCBF